
1 / 1
Design Ready-to-Use Robot Motion Datasets | Virdyn Planning, Solution
Product Description
| Module | Key Information | Description & Customer Value |
|---|---|---|
|
Module 1 Dataset Overview |
Name: 140+ Humanoid Robot Motion Datasets Compatible Model: Unitree G1 Humanoid Robot (29-DOF version) |
A high-quality, ready-to-use pre-programmed motion library specifically built for the Unitree G1 robot, containing over 140 motions. |
|
Module 2 Content & Categories |
Number of Motions: > 140 Motion Categories: Divided into 6 major types:
|
Rich and diverse motions covering scenarios from basic control to advanced demonstrations, meeting various needs for R&D, demos, and entertainment. |
|
Module 3 Data Acquisition & Production |
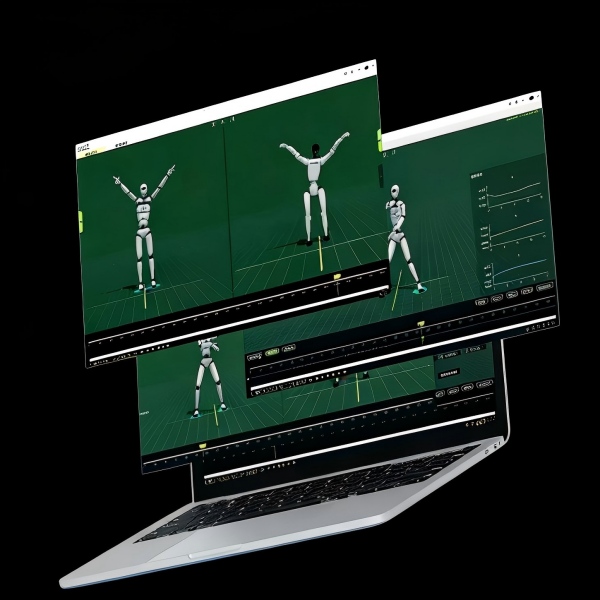
Capture Equipment: Virtual full-body inertial motion capture system and software. Production Pipeline: A three-stage refinement process:
|
Motions originate from natural human movements, with dual assurance from professional algorithms and manual verification. This ensures motions are both fluid and natural and conform to the target robot's physical constraints, not simply algorithmically generated. |
|
Module 4 Core Technical Standards (Quality Assurance) |
|
Core promise of "Ready-to-Use, Safe & Reliable". All motions undergo strict validation and can be directly used for robot control, significantly reducing the difficulty and risk for developers in programming and debugging motions themselves, while ensuring hardware safety. |
|
Module 5 Data Specifications |
Data Content: Per-frame robot joint position, posture, and motor rotation data. Coordinate System: Adapted to the Unitree G1 robot base coordinate system (origin at chassis center, X-axis forward, Y-axis left, Z-axis up). Data Format: Plain-text CSV files, UTF-8 encoding, fields separated by tabs ( \t).File Structure: Stored in "Scene-Action Name" format for easy management. |
Standard, open data format. Can be directly imported into your control framework or simulation software for use without additional coordinate conversion—truly plug-and-play. |
Core Value Proposition: This dataset provides you with a set of industrially produced and validated, ready-to-use high-quality robot motion solutions. It helps you quickly achieve robot functionality demonstrations, algorithm testing (e.g., reinforcement learning), or actual application deployment, saving months of motion programming and debugging time.
The Dataset: A Comprehensive Foundation for Robot Behavior
Our dataset is engineered to provide a robust foundation for a wide range of applications, from basic mobility to complex human-robot interaction.
Core Specifications:
- Total Motions: 140+ individual skill sequences
- Target Platform: Optimized for Unitree G1 29-DOF kinematics
- Format: Clean, timestamped CSV files with joint position trajectories
- Validation: All motions tested for stability and feasibility in a dynamic simulator
Frequently Asked Questions (FAQ)
Which robot hardware model is this dataset compatible with?
The dataset is specifically customized and mathematically mapped for the Unitree G1 Humanoid Robot (29-DOF version).
What file formats are provided for the motion sequences?
The trajectories are delivered as standard plain-text CSV files encoded in UTF-8, using tab delimiters (\t) for direct compatibility with custom control frameworks and simulation environments.
How is hardware safety ensured during motion playback?
The dataset strictly complies with a 0% over-limit rate for motor rotation angles. Every trajectory maintains motor change rates below hardware thresholds and has been verified in dynamic simulation to eliminate motor jitter and joint overload.
What coordinate system does the data use?
All motion files are adapted to the Unitree G1 robot base coordinate system: chassis center as origin, X-axis pointing forward, Y-axis pointing left, and Z-axis pointing up.
How was the motion capture data generated and refined?
Data was captured via virtual full-body inertial motion capture, processed through retargeting algorithms tailored to the 29-DOF kinematic model, and then manually verified frame-by-frame to correct any joint anomalies.
What types of motion categories are included?
The 140+ motion collection includes six primary categories: Basic Motions, Functional Actions, Dance Motions, Talent Motions (such as martial arts and gymnastics), Holiday-Themed Motions, and Humorous Motions.









